Mobile robots · Primary: ISO 3691-4
AGV & AMR compliance without the guesswork
Driverless industrial trucks and autonomous mobile robots — navigation safety, protective fields, battery/charging, and fleet interfaces for EU, UK, and North America.
Built for: Mobile robot OEMs and integrators
 ISO 3691-4
What this category actually demands
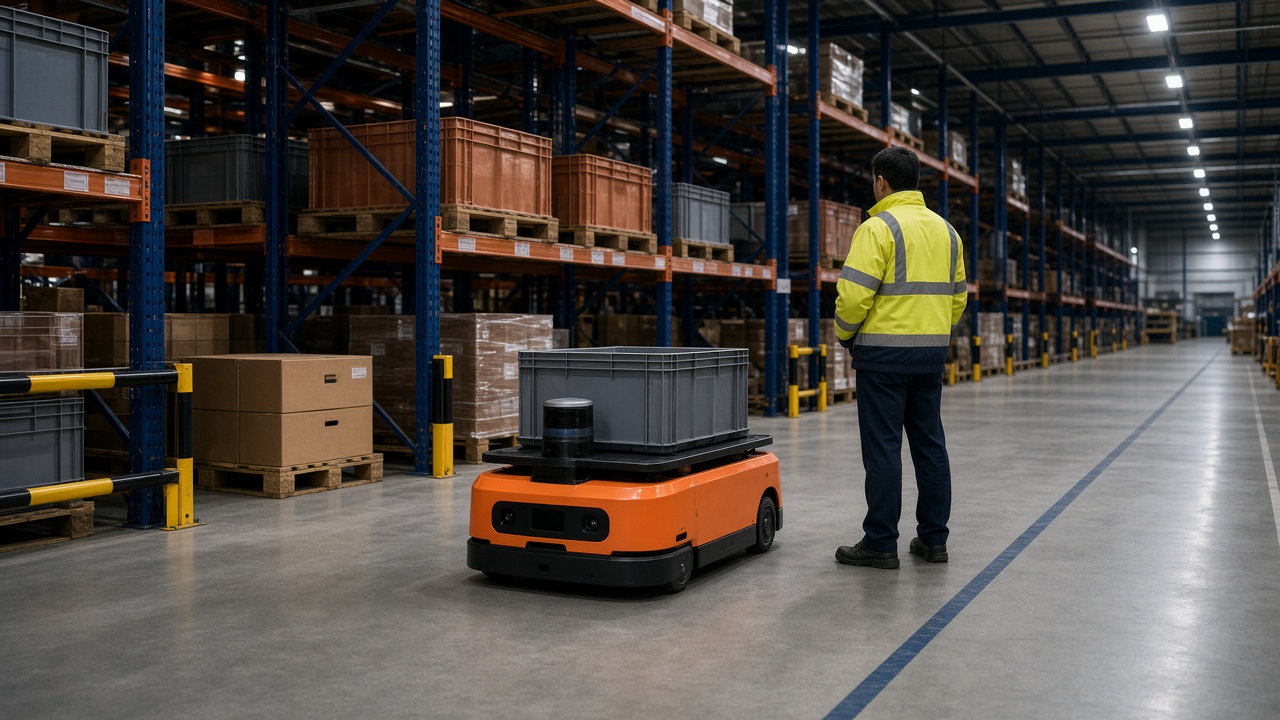
AGVs follow defined guidance; AMRs navigate freely. They share ISO 3691-4 roots but validate differently. Start on the dedicated pages — AMR for free navigation and fleet behaviour, AGV for guided paths and load handling — then use this overview if your platform spans both.
Whichever type you build, the pattern is constant: define where it operates, prove how it protects people, and keep route, map, and software changes inside change control.
Reality check
Where AGVs & AMRs programs stall
Wrong type-C starting point
Applying a generic machinery checklist without ISO 3691-4 leaves the questions customers actually ask unanswered.
Component certificates mistaken for system approval
Scanners, controllers, and drives are evidence. The vehicle system claim is yours.
Safety architecture — AGVs & AMRs
The safety architecture we build with you
Every function below ends as a claim in your file — with a target performance level, an implementation, and a validation method. If one of these is missing for your product, that is where we start.
Protective fields & safe speed
Sized and validated for the actual vehicle and payload.
Safe stop & recovery
Designed behaviour for faults, localisation/guidance loss, and remote stop.
How we help — from first sketch to site acceptance
One path, four gates. You keep design authority; we own the compliance thread through labs, assessors, and customer EHS reviews.
Gate 1
Domain & classification
Where it operates, who is exposed, which laws and type-C standards actually apply — before any test is booked.
Gate 2
Risk & safety architecture
ISO 12100 assessment turned into safety functions with PL/SIL targets your controls team can implement.
Gate 3
Validation
Measurements and tests on the real configuration — payload, speed, workpiece, ground — that close each safety claim.
Gate 4
File & acceptance
Technical file, DoC/DoI, instructions, and the site/customer acceptance pack, with change control that keeps it valid.
What you receive
- Machinery classification & EHSR map
- ISO 12100 risk assessment
- Protective-field & speed-control validation plan
- Battery / charger evidence pack (UN 38.3, IEC 62133 where applicable)
- Technical file, DoC, and residual-risk instructions
Standards, in context
These are starting points, not a shopping list. The applicable editions and clauses follow from your classification and markets — EU Machinery Regulation (EU) 2023/1230, UK machinery rules, or North American OSHA/ANSI expectations, layered with EMC, electrical, radio, and battery law where your product triggers them.
| ISO 3691-4 | Driverless industrial trucks and their systems — safety |
| EN ISO 12100 | Risk assessment and risk reduction |
| EN ISO 13849-1 / IEC 62061 | Safety-related control systems (PL / SIL) |
| EN IEC 60204-1 | Electrical equipment of machines |
| ANSI/ITSDF B56.5 / R15.08 (as applicable) | North American driverless / mobile robot guidance |
Questions we hear from AGVs & AMRs teams
Is an AMR “machinery” in the EU?+
Usually yes when it performs a machinery function. Expect Machinery Regulation, EMC, RED (if radios), and battery obligations together.
Does fleet software change the file?+
Yes. Safety functions in fleet managers, remote stop, and map updates belong in the risk assessment and change control.
Bring us your project — at any stage
Sketch, prototype, or a customer audit next month. A 30-minute scoping call maps your domain, standards, and evidence gaps.
Book Free CallKeep exploring Robotics
All Robotics →Mobile robots
AMRs — Autonomous Mobile Robots
Free-navigation mobile robots for factories, warehouses, hospitals & intralogistics fleets.
Mobile robots
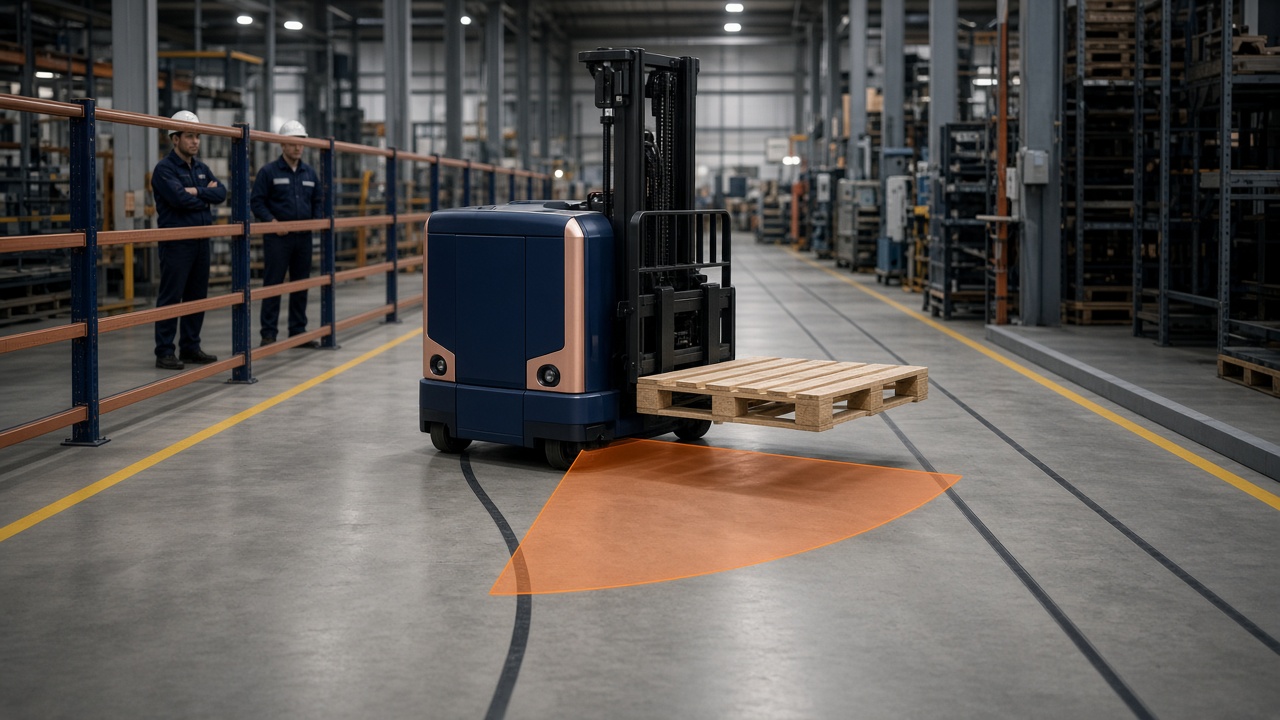
AGVs — Automated Guided Vehicles
Guided vehicles, automated forklifts & tuggers on defined paths — guidance, load & plant interfaces.
Mobile robots
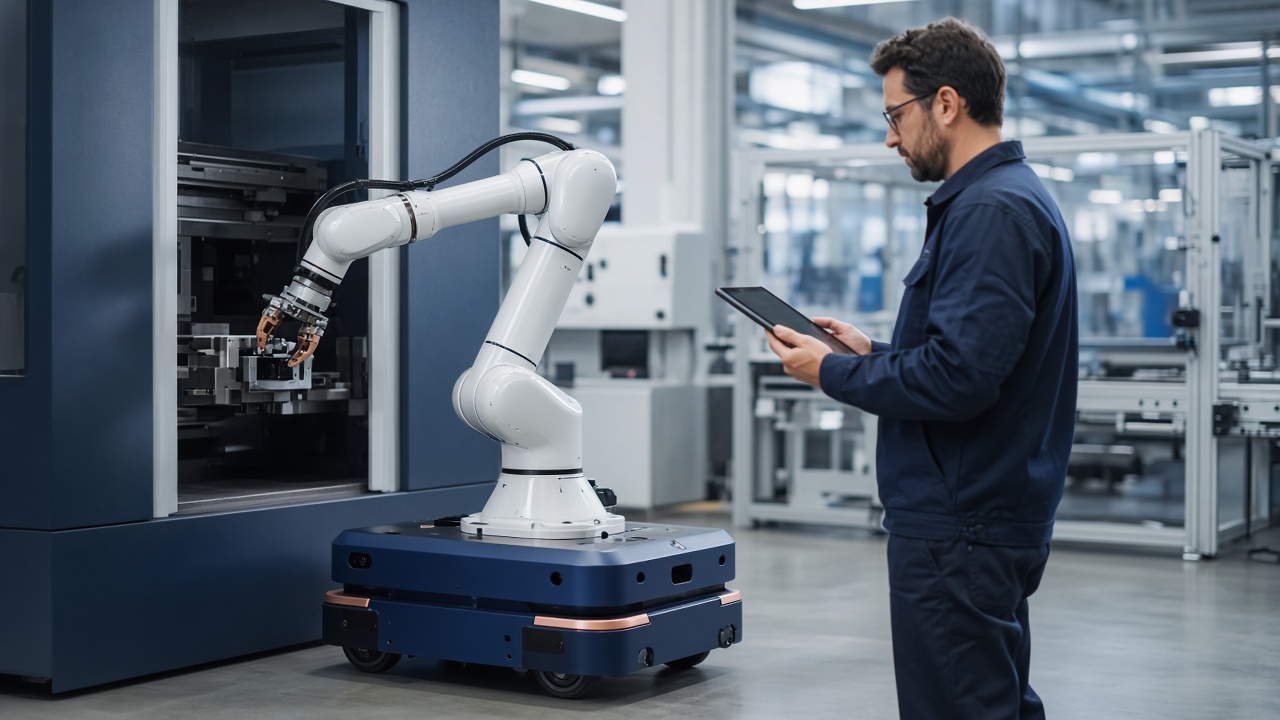
Mobile Manipulators (MoMas)
A mobile base plus a robot arm — combined navigation, manipulation, and collaborative risks.