Collaborative & industrial robots · Primary: EN ISO 12100 (stack)
Humanoid & legged robot compliance for pilot deployments
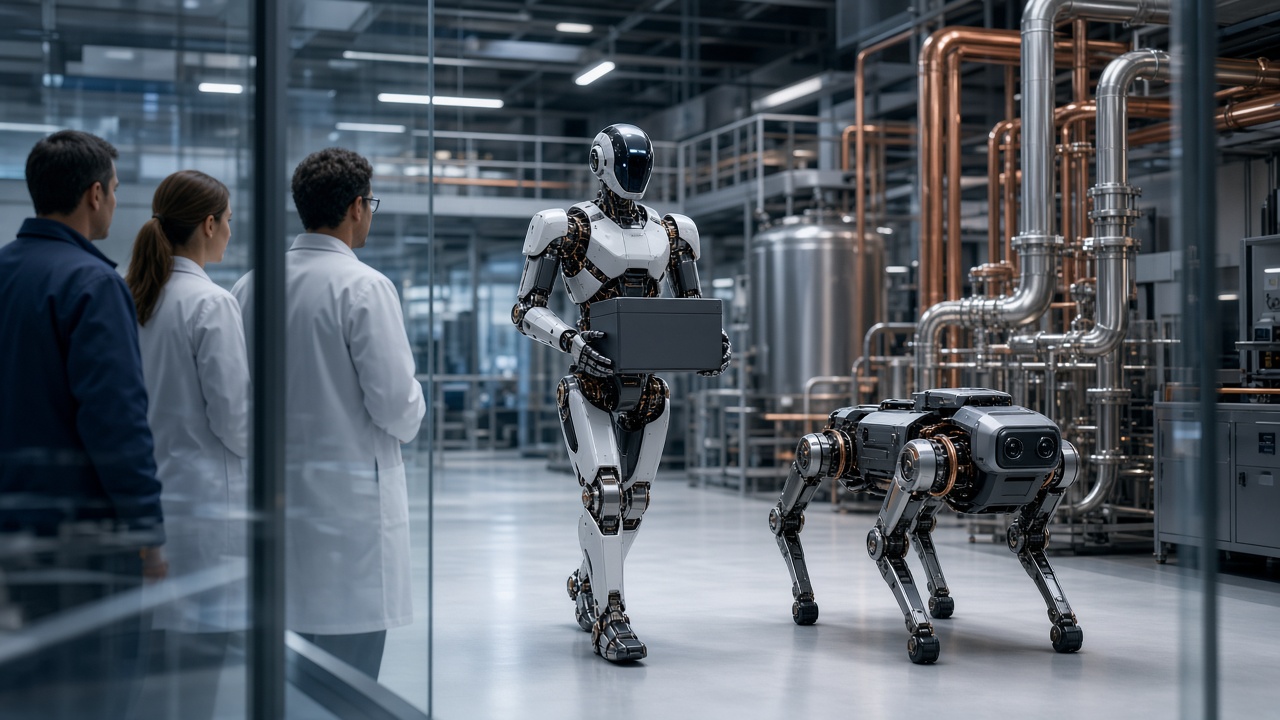
No single “humanoid standard” — we stack machinery, functional safety, battery, RF, EMC, and increasingly cyber/AI expectations into a defensible pilot file.
Built for: Humanoid & legged robot OEMs, pilot program leads, and enterprise innovation/EHS teams
 EN ISO 12100 (stack)
What this category actually demands
There is no “humanoid certification” to buy. Sites that approve pilots approve a bounded operational domain, a predictable fallback when perception or balance degrades, and a battery/EMC/RF file that looks like any other serious machine. Teams that arrive with that story deploy; teams that arrive with a demo reel do not.
We assemble the stack — ISO 12100 risk assessment, safety-related controls, battery and radio evidence, human-interaction rationale — into a pilot safety case your customer’s EHS board can actually approve, with the residual risks stated plainly.
Reality check
Where Humanoids & Legged Robots programs stall
Demo defined the domain
The pilot site is not your lab: different floors, people, lighting, and network. Domain first, then behaviour claims inside it.
Learned behaviour with no boundary story
You do not certify a neural network’s intentions. You bound what the machine may do, monitor it, and design the fallback when confidence drops.
Battery and radio left to the end
Large traction batteries and always-on radios carry UN 38.3 / IEC 62133, RED/FCC, and increasingly cyber obligations that gate shipping, not just safety review.
Safety architecture — Humanoids & Legged Robots
The safety architecture we build with you
Every function below ends as a claim in your file — with a target performance level, an implementation, and a validation method. If one of these is missing for your product, that is where we start.
Bounded operational domain
Where, with whom, at what speed/payload — and what is explicitly out of scope for the pilot.
Fallback & loss-of-link
Designed safe behaviour for perception loss, balance faults, and comms loss — tested, not logged.
Human interaction limits
Contact, speed, and separation rationale for whole-body mobile platforms near people.
Energy & connectivity file
Battery safety/transport, EMC/RF, and update/cyber process as one evidence map.
How we help — from first sketch to site acceptance
One path, four gates. You keep design authority; we own the compliance thread through labs, assessors, and customer EHS reviews.
Gate 1
Domain & classification
Where it operates, who is exposed, which laws and type-C standards actually apply — before any test is booked.
Gate 2
Risk & safety architecture
ISO 12100 assessment turned into safety functions with PL/SIL targets your controls team can implement.
Gate 3
Validation
Measurements and tests on the real configuration — payload, speed, workpiece, ground — that close each safety claim.
Gate 4
File & acceptance
Technical file, DoC/DoI, instructions, and the site/customer acceptance pack, with change control that keeps it valid.
What you receive
- Pilot-scope risk assessment & operational design domain
- Fallback / loss-of-link & e-stop strategy
- Battery, RF, EMC evidence map
- Human-interaction & force-limiting rationale
- Site pilot safety case inputs
Standards, in context
These are starting points, not a shopping list. The applicable editions and clauses follow from your classification and markets — EU Machinery Regulation (EU) 2023/1230, UK machinery rules, or North American OSHA/ANSI expectations, layered with EMC, electrical, radio, and battery law where your product triggers them.
Go deeper: Humanoid robot safety & compliance stack →
| EN ISO 12100 | Risk assessment (no dedicated humanoid type-C yet) |
| EN ISO 13482 (where applicable) | Personal care / service robot safety concepts |
| EN ISO 13849-1 / IEC 62061 | Safety-related controls |
| IEC 62133 / UN 38.3 | Battery safety & transport |
| RED / CRA (as applicable) | Radio & connected-product cyber expectations |
Questions we hear from Humanoids & Legged Robots teams
What certifies a humanoid?+
A stack, not a stamp: machinery risk assessment, control-system safety, electrical/battery, EMC/RF, and site rules together.
Bring us your project — at any stage
Sketch, prototype, or a customer audit next month. A 30-minute scoping call maps your domain, standards, and evidence gaps.
Book Free CallKeep exploring Robotics
All Robotics →
Collaborative & industrial robots
Robot Arms
Articulated, SCARA, delta & Cartesian arms as products — ISO 10218-1 OEM evidence integrators can build on.
Collaborative & industrial robots
Cobots & Collaborative Applications
Collaborative robot applications — power & force limiting, hand-guiding, and speed/separation monitoring.
Collaborative & industrial robots
Industrial Robots & Robot Cells
Articulated, SCARA, delta, and Cartesian robots — fenced, interlocked, and integrated cells.