Heavy & field machinery · Primary: EN ISO 12100 + type-C neighbours
Construction robot compliance: the site is the system
Robots for bricklaying, rebar tying, demolition, drilling, layout, and surveying — remote/autonomous mode control, multi-employer sites, and handover packs principal contractors accept.
Built for: Construction robot OEMs — bricklaying, rebar, demolition, drilling, layout & surveying robots
 EN ISO 12100 + type-C neighbours
What this category actually demands
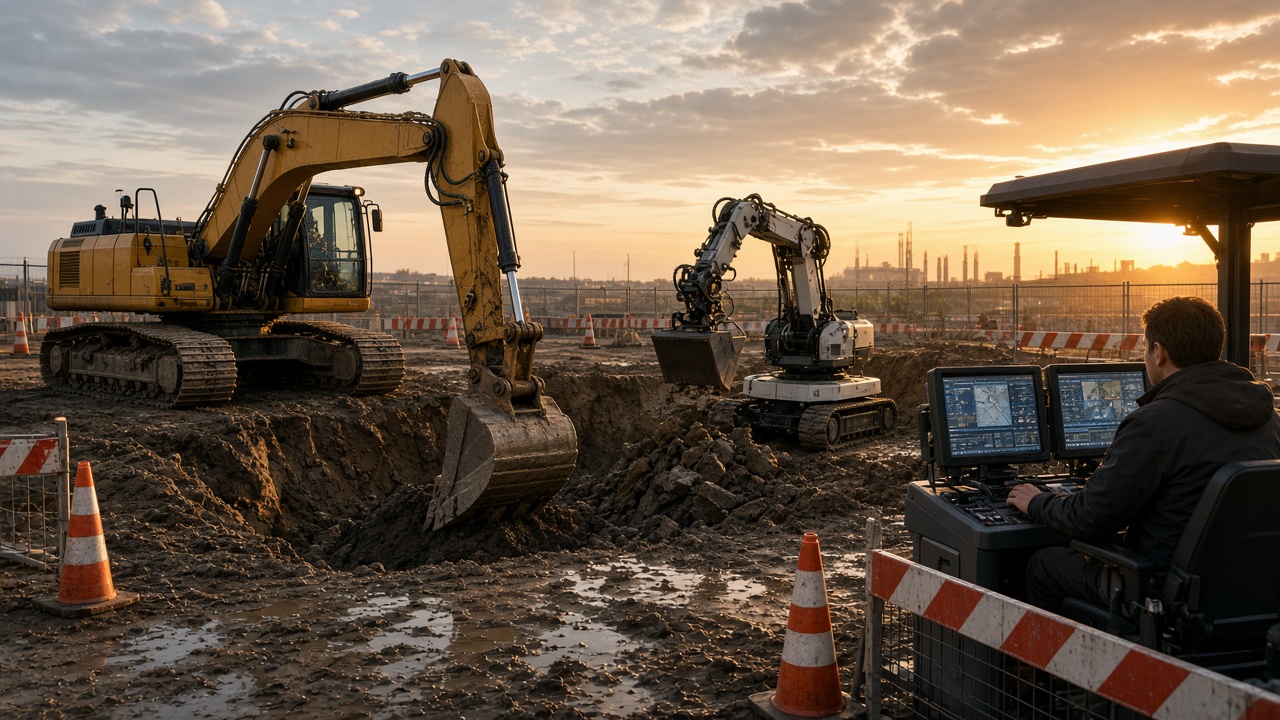
A construction robot leaves the factory problem behind: uneven ground, dust, weather, other trades, and heavy plant moving around it. Its compliance story is therefore a site story — operational domain, remote/autonomous mode control, and interaction with people who never read its manual.
We scope construction robots under machinery law with the right type-C neighbours (earth-moving, cranes, or powered access where they touch), design the remote-operation safety functions, and build the site-handover pack contractors and principal designers increasingly demand before a robot sets foot on site.
Reality check
Where Construction Robots programs stall
Factory risk assessment shipped to a site
Ground conditions, public interface, and multi-employer coordination change the hazard set fundamentally. Site-specific assessment is not paperwork duplication.
Remote control as an accessory
Link loss, latency, operator identity, and mode authority are primary safety functions on a remote demolition or drilling robot.
No handover story for the principal contractor
Sites run on RAMS and competence records. A robot without a handover pack waits at the gate.
Safety architecture — Construction Robots
The safety architecture we build with you
Every function below ends as a claim in your file — with a target performance level, an implementation, and a validation method. If one of these is missing for your product, that is where we start.
Mode & authority control
Manual / remote / autonomous modes with unambiguous operator authority and transfer.
Loss-of-link safe state
Designed stop/hold behaviour on link degradation, tested under site-realistic interference.
Exclusion & detection
Person/plant detection and physical exclusion matched to the task’s energy (demolition ≠ layout printing).
Site handover pack
RAMS inputs, competence, inspection, and emergency procedures a principal contractor can file.
How we help — from first sketch to site acceptance
One path, four gates. You keep design authority; we own the compliance thread through labs, assessors, and customer EHS reviews.
Gate 1
Domain & classification
Where it operates, who is exposed, which laws and type-C standards actually apply — before any test is booked.
Gate 2
Risk & safety architecture
ISO 12100 assessment turned into safety functions with PL/SIL targets your controls team can implement.
Gate 3
Validation
Measurements and tests on the real configuration — payload, speed, workpiece, ground — that close each safety claim.
Gate 4
File & acceptance
Technical file, DoC/DoI, instructions, and the site/customer acceptance pack, with change control that keeps it valid.
What you receive
- Site operational domain & task risk assessment
- Remote-operation safety-function design
- Stability & ground-condition envelope
- Principal-contractor handover pack (RAMS inputs)
- Technical file, DoC & operator competence inputs
Standards, in context
These are starting points, not a shopping list. The applicable editions and clauses follow from your classification and markets — EU Machinery Regulation (EU) 2023/1230, UK machinery rules, or North American OSHA/ANSI expectations, layered with EMC, electrical, radio, and battery law where your product triggers them.
Go deeper: Earth-moving & construction machinery compliance →
| EN ISO 12100 | Risk assessment — site operational domain |
| ISO 20474 / EN 474 neighbours (where applicable) | Earth-moving & site machinery interfaces |
| EN ISO 13849-1 | Safety-related controls incl. remote operation |
| Outdoor Noise 2000/14/EC (where applicable) | Noise emission for outdoor equipment |
Questions we hear from Construction Robots teams
Who approves a robot on a construction site?+
Beyond product law, the principal contractor’s site rules decide admission. A handover pack aligned to their RAMS process is what gets robots through the gate.
Bring us your project — at any stage
Sketch, prototype, or a customer audit next month. A 30-minute scoping call maps your domain, standards, and evidence gaps.
Book Free CallKeep exploring Robotics
All Robotics →Heavy & field machinery
Earth-Moving & Construction Machinery
Excavators, loaders, dozers, telehandlers, and increasingly autonomous / remote-controlled site machinery.
Heavy & field machinery
Agricultural & Forestry Robots & Machinery
Tractors, implements, agricultural robots, harvesters, and forestry machinery — field, road, and bystander risks.
Heavy & field machinery
Mining, Outdoor & Field Robots
Inspection, delivery, cleaning, and service robots operating outdoors, underground, or in harsh / remote sites — including hazloc interfaces.